Portfolio

Sachin
Thakur

Robotics & machine learning engineer

I build perception and learning systems for robots: vision transformers, 6-DoF pose estimation, Isaac Sim digital twins, and the hardware they run on. Currently at Luminous Robotics in Boston, working with AWS and NVIDIA on a Physical AI challenge.

1 of 9 companies selected worldwide for the AWS × NVIDIA Physical AI program, on a data pipeline I built.

300 → 110 ms end-to-end inference latency on a production vision transformer.

$15,000 grant from BITSAA to build a low-cost autonomous quadruped.

Experience

Jan 2026 – now
South Boston, MA

Robotics Engineer, ML Luminous Robotics

  • Built the Physical AI data-collection pipeline behind the company's AWS × NVIDIA grant, one of nine companies selected globally; I now work directly with both teams on the challenge.
  • Build digital twins in NVIDIA Isaac Sim for robot simulation, synthetic data collection, and testing as part of a Digital Twin fellowship.
  • Implemented and fine-tuned 6-DoF pose estimators (FoundationPose, EfficientPose, CenterPose, DOPE) for robust real-world performance.
  • Maintain and debug the full robot stack: ROS 2, networking, deployment, and calibration.
Jun 2024 – Dec 2025
Bedford, MA

Machine Learning Scientist Oxipital AI

  • Cut panoptic segmentation training from 4 to 3 days and false positives by 15%, with PQ held, by implementing ReMaX-inspired optimizations (ReMask + ReClass) in PyTorch.
  • Built a DINOv3-style self-supervised backbone and the data infrastructure for training a foundation vision model.
  • Redesigned the vision transformer for memory-efficient, variable-resolution training; higher-resolution inputs raised PQ by 5% at comparable cost.
  • Cut sensor-data storage by about 60% by designing binary and sparse HDF5 representations, which also sped up training and inference.
  • Led the inference pipeline redesign across GPU, container, and on-prem environments:
Jun 2022 – Jun 2023
Bengaluru, India

Analyst, AI & Data Engineering Deloitte USI

  • Delivered end-to-end time-series forecasting systems and Monte Carlo risk models used in multi-million-dollar decisions.
  • Deployed models on AWS SageMaker with auto-scaling; AWS AI/ML certified.
Nov – Dec 2021
Braunschweig, Germany

Visiting Researcher TU Braunschweig

  • Mentored 20 students from Germany and India on sustainable EV business models and researched PLC applications for Industry 4.0.

Projects

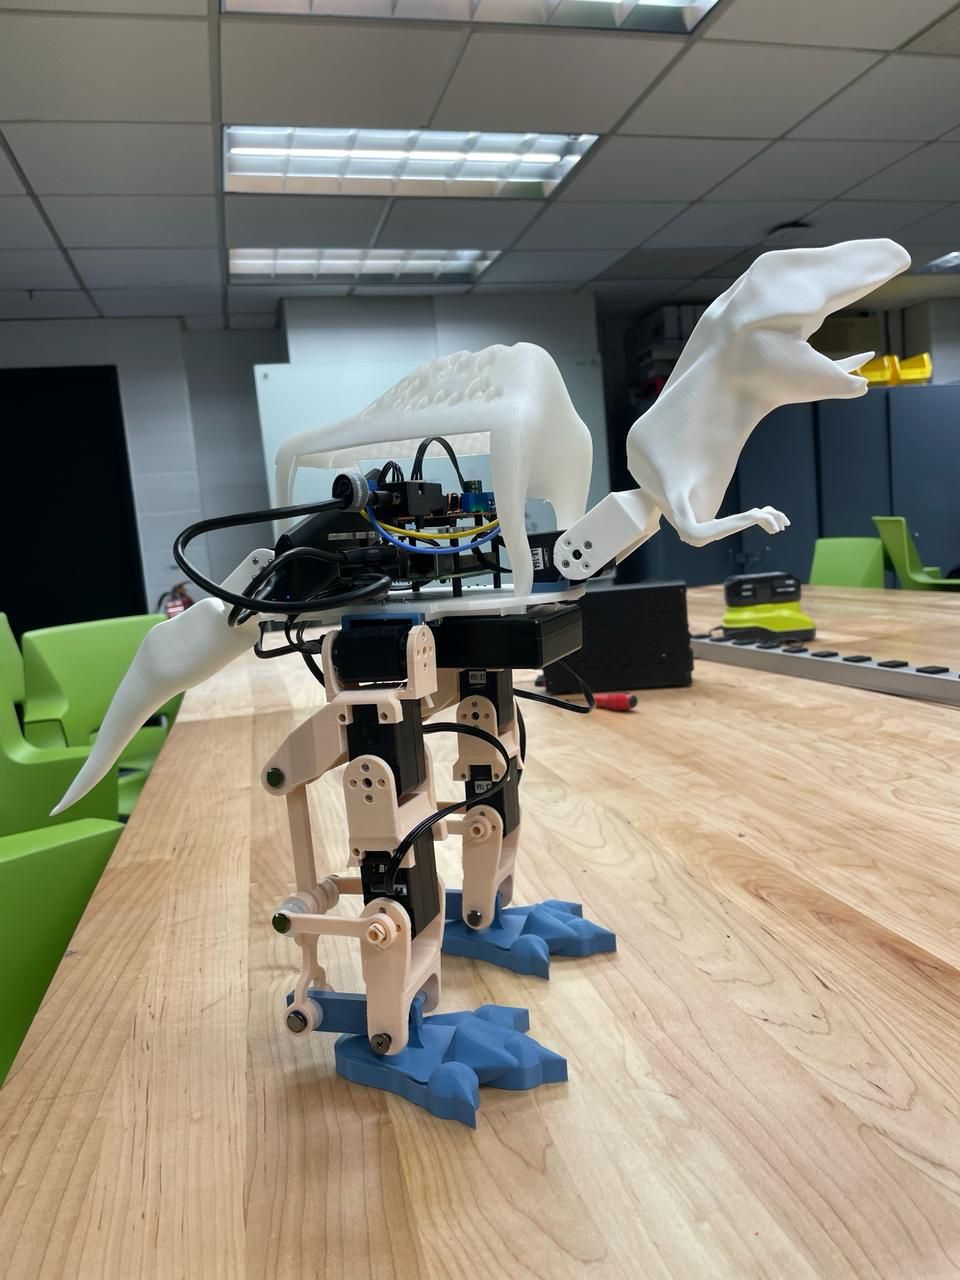
Trex, a 3D-printed bipedal robot with a dinosaur shell, standing on a lab table

Trex, an adaptive bipedal robot

A 1.6 kg, 10-DoF dinosaur biped I designed in Fusion 360 and 3D-printed. Walking policies trained entirely in simulation now run on the real robot's own Raspberry Pi.

  • Trained with asymmetric PPO in Isaac Sim 6 and ported the setup bit-identically to Isaac Lab: the policy sees only what the robot can sense (BNO055 IMU and LX-16A servo feedback), while the critic trains on privileged state.
  • Fitted a servo model to the real servos, then refit it to the robot's own walking logs (1.4° RMS). Built a MuJoCo check that runs every policy through the exact Pi control loop before it touches hardware.
  • In simulation, 98–100% of episodes survive 20 s at 0–0.15 m/s. On the real floor the best policy has walked 0.41 m in 10 s; closing that sim-to-real speed gap is the current focus.

Isaac Sim 6, Isaac Lab, MuJoCo, PyTorch, PPO, Raspberry Pi

Trex's legs stepping across a wooden floor under a learned policy
Trex walking on hardware with a policy trained only in simulation. Shown at 4× speed.
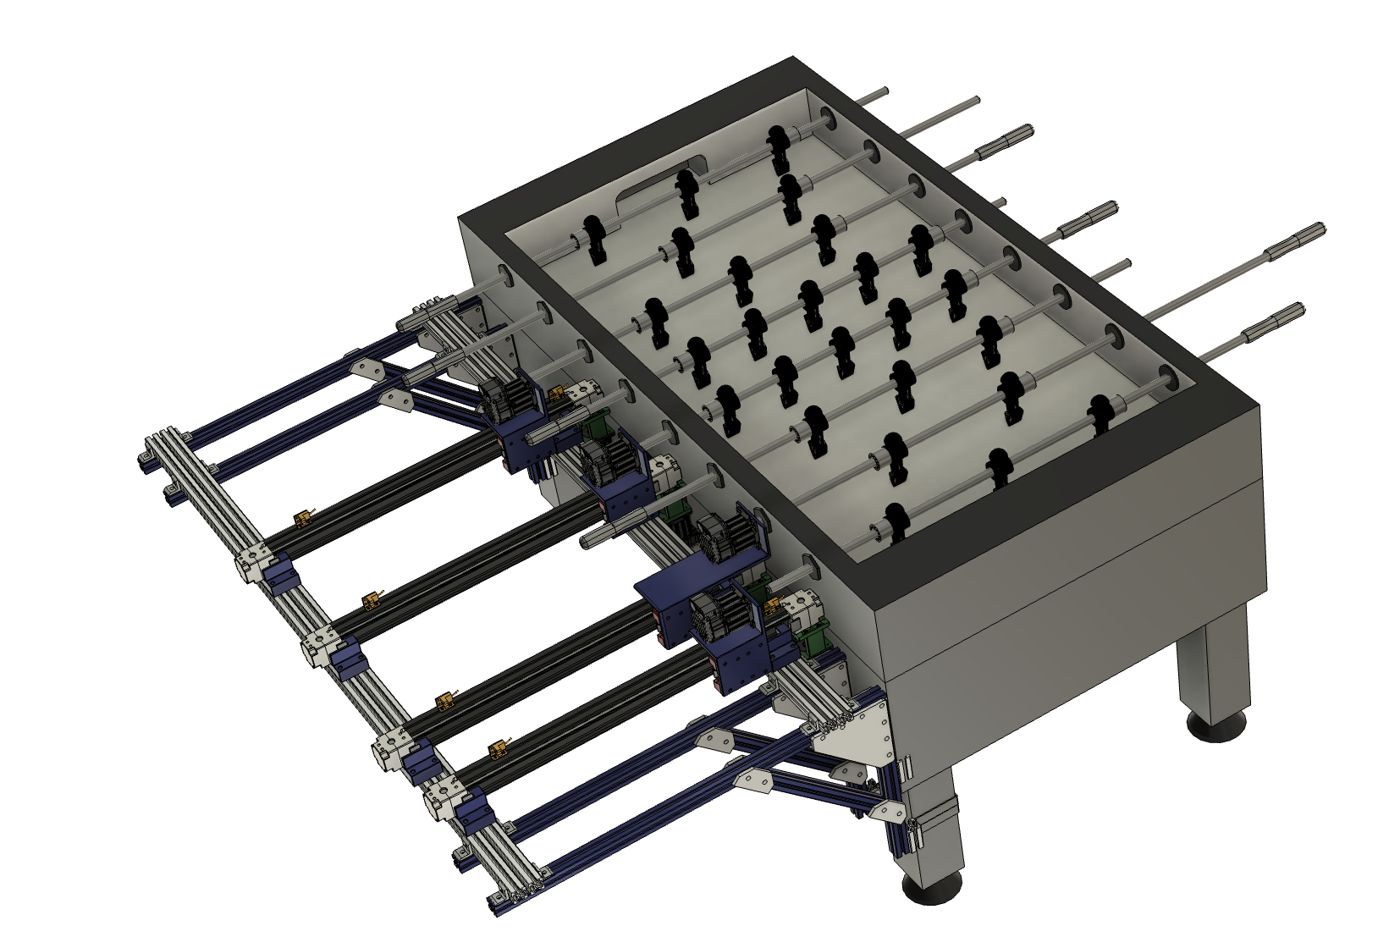
CAD model of a foosball table with motorized linear and rotary actuators on every rod

Foosball AI at Columbia

A robot that plays professional foosball. I built the high-fidelity Isaac Sim simulator, with realistic table dynamics and contact modeling, used to train the RL agents that drive motorized rods on the real table.

  • Modeled the physical table from CAD to URDF so policies transfer from sim to real.
  • Soft actor-critic agents trained through protagonist–antagonist self-play, driving ClearPath servo motors on the real rods.
  • Co-authored the NeurIPS 2024 paper presenting it as an end-to-end deep RL platform for competitive physical systems.

Isaac Lab, MuJoCo, Stable-Baselines3, C++, SolidWorks

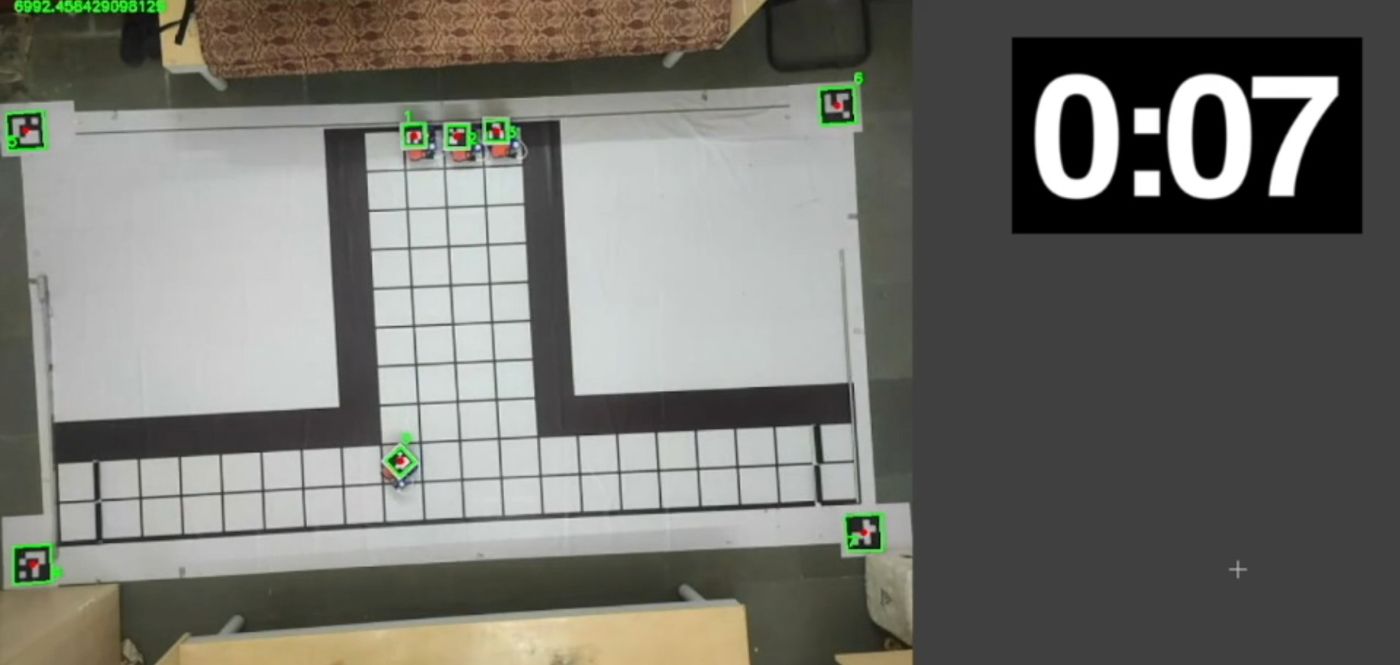
Overhead camera view of an arena with ArUco-tagged delivery robots

Collaborative delivery robots

A swarm of small robots that split up package deliveries, using multi-agent path planning and task allocation with overhead mono-camera SLAM. Built for a national robotics competition.

OpenCV, SLAM, path planning, microcontrollers

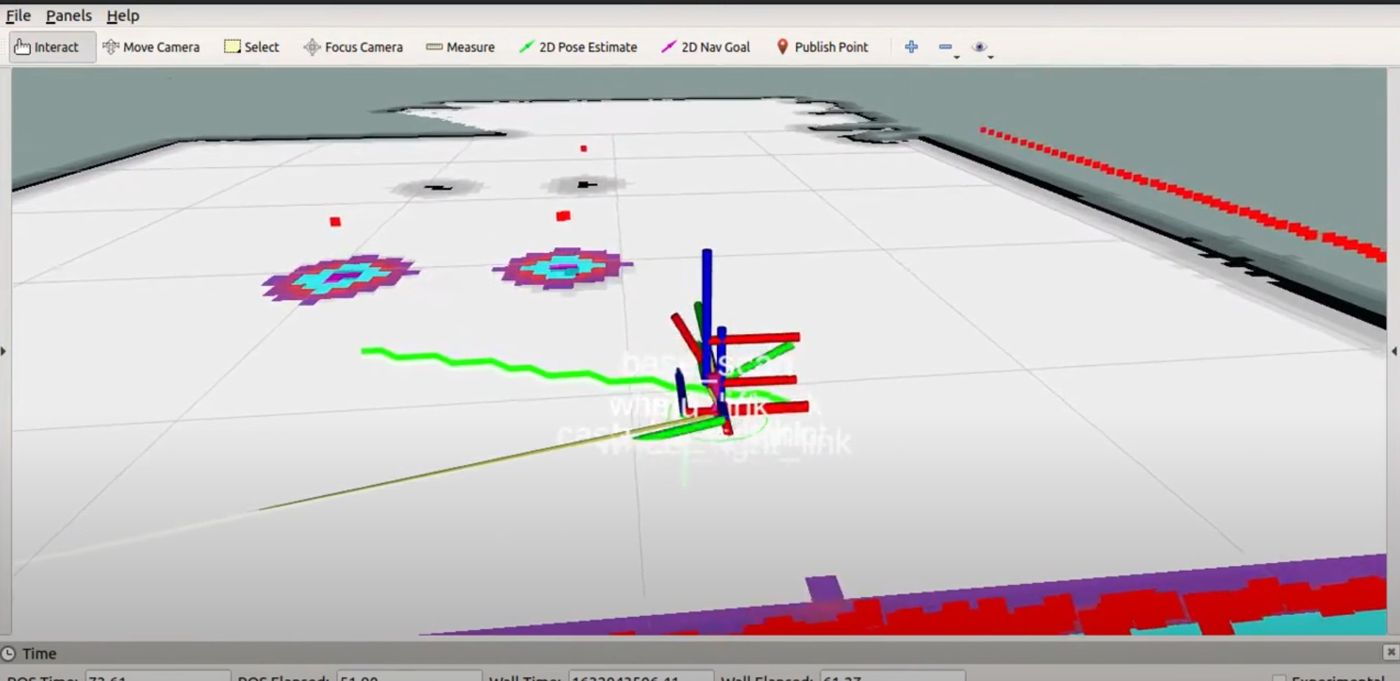
RViz view of a vehicle's planned path and LiDAR obstacles

Autonomous driving stack

Built a modular self-driving pipeline: CNN lane detection, YOLO object recognition, and fusion of LiDAR, RGB camera, and GPS for real-time path planning in ROS 2.

ROS 2, YOLO, sensor fusion, NumPy

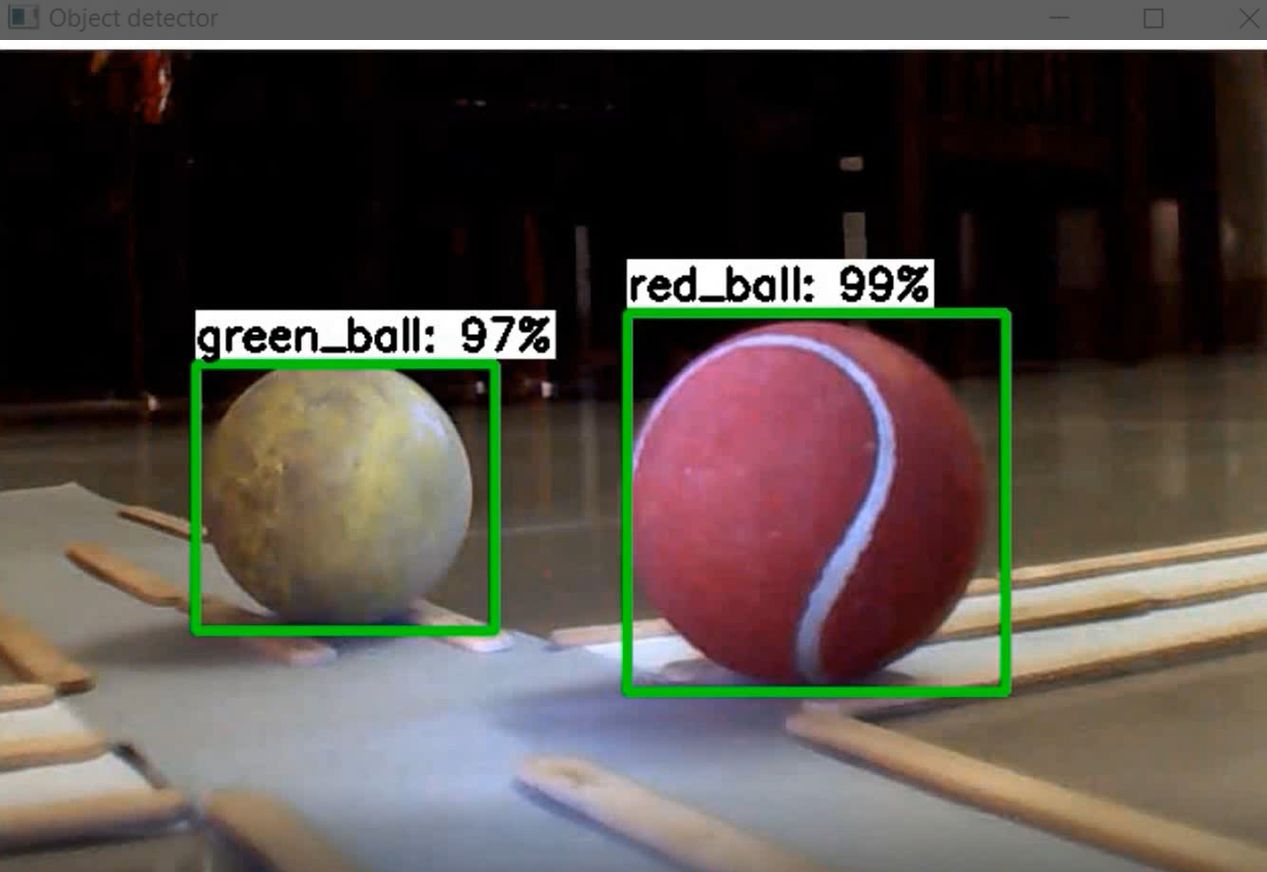
Object detector output with bounding boxes at 97 and 99 percent confidence

Smart traffic monitoring

Deployed YOLOv5 on Raspberry Pi edge devices, streaming into a Flask service for lane prioritization and emergency-vehicle preemption. Designed it to survive patchy connectivity and cut simulated delays by 15%.

YOLOv5, Raspberry Pi, Flask, IoT

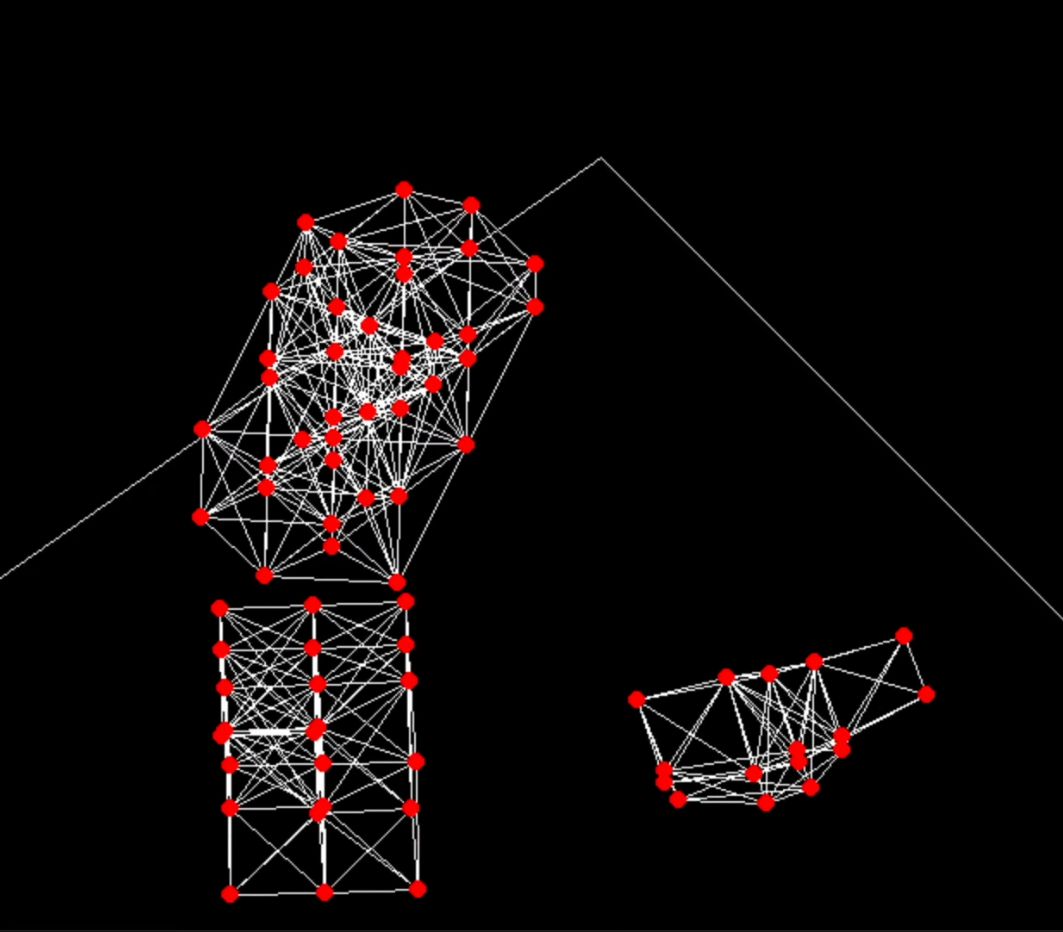
Spring-mass soft robot morphologies rendered as red nodes and white springs

Evolving soft robots

Wrote genetic algorithms that co-evolve the body and gait of spring-mass robots in simulation, tuned for faster convergence and more resilient walkers.

Python, evolutionary algorithms, physics simulation

More work

Publications

NeurIPS, Dec 2024

End-to-end deep reinforcement learning platform for competitive physical dynamic systems

A high-fidelity Isaac Sim foosball simulator with realistic dynamics and contact modeling, used to train competitive AI agents for a real table.

Toolkit

Vision & deep learning
PyTorch, TensorFlow, Vision Transformers, DINO-style SSL, panoptic segmentation, 6-DoF pose estimation, YOLO, ConvNeXt
Inference & performance
ONNX, TensorRT, FP16 / INT8 quantization, pruning, NVIDIA Nsight, multi-GPU DDP
Robotics & simulation
ROS 2, Isaac Sim, Isaac Lab, MuJoCo, Gazebo, PyBullet, URDF, RL (PPO, A3C, SAC), MPC, PID
Hardware
Jetson, Raspberry Pi, Arduino, IMUs, LiDAR, depth cameras, calibration
Engineering
Python, C++, Bash, FastAPI, Flask, Docker, Kubernetes, AWS, MLflow, HDF5, MCAP, MongoDB

Education

M.S. Mechanical Engineering

Columbia University, 2023 – 2024. Minor in robotics and control.

Robotics, AI, applied robotics, Robot Studio, control theory, evolutionary algorithms

B.E. Mechanical Engineering

BITS Pilani, 2018 – 2022

Computer vision, nonlinear dynamics and chaos, IoT, additive manufacturing

Sachin Thakur

Let's build something that moves.

I'm open to conversations about robot learning, perception, and simulation, whether that's a role, a research collaboration, or a hard problem you're stuck on.